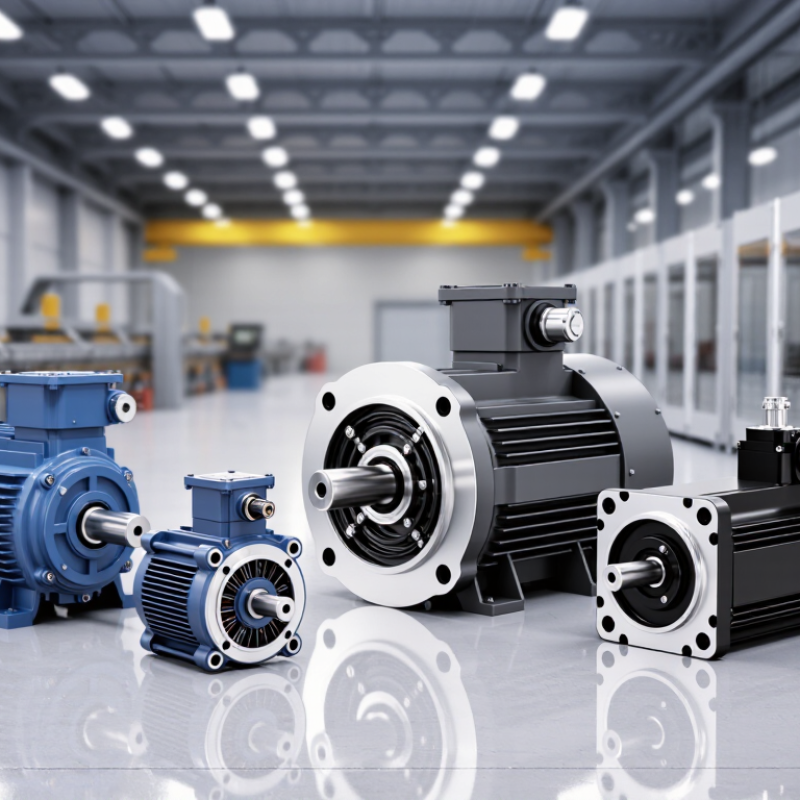
| AC Induction Motor |
An alternating-current stator field induces current in the rotor, producing torque. Squirrel-cage designs are widely used in industry. |
Pumps, fans, compressors, conveyors, mixers, and general-purpose machinery. |
Robust construction, broad availability, and relatively straightforward maintenance. |
Speed varies with load when operated directly from the supply. A variable-frequency drive can provide adjustable speed and controlled starting. |
Direct-on-line starter or variable-frequency drive (VFD). |
| Synchronous Motor |
The rotor turns in step with the rotating magnetic field of the stator once synchronized with the supply. |
Large compressors, pumps, mills, and applications requiring constant speed or power-factor support. |
Runs at a speed determined by supply frequency and pole count; some designs can provide adjustable power-factor operation. |
Starting and control arrangements are more involved than for many induction motors. Suitability depends on the load and operating requirements. |
Supply-frequency operation or a drive system, depending on the design. |
| Permanent-Magnet Synchronous Motor (PMSM) |
Permanent magnets on or in the rotor interact with the stator’s controlled rotating field to produce synchronous torque. |
Servo axes, precision machinery, robotics, and compact, efficient drive systems. |
High torque and power density; can offer high efficiency across a suitable operating range. |
Usually needs an electronic drive and suitable feedback or sensorless control. Permanent magnets can add material and temperature-management considerations. |
Inverter-based vector control, often with encoder or resolver feedback. |
| Brushless DC Motor (BLDC) |
Electronic switching energizes stator windings in sequence; permanent magnets are typically fitted to the rotor. |
Small pumps, fans, material-handling equipment, and compact automated machinery. |
No mechanical brushes to replace; electronic commutation supports controllable speed. |
Requires an electronic controller. Naming and construction can overlap with permanent-magnet synchronous motor terminology, depending on commutation and waveform conventions. |
Electronic commutation using position sensors or sensorless control. |
| Switched Reluctance Motor |
Precisely timed stator currents pull a toothed, magnetically permeable rotor toward positions of lower magnetic reluctance. |
Selected pumps, fans, compressors, and applications where a simple rotor construction is useful. |
Rotor has no windings or permanent magnets; performance can be tailored through electronic control. |
Needs a dedicated power converter and control strategy. Torque ripple and acoustic noise may require attention in system design. |
Dedicated electronic converter with rotor-position-based switching. |
| Brushed DC Motor |
Brushes and a commutator switch current in the rotor windings to maintain torque as the rotor turns. |
Legacy machinery, battery-powered equipment, and applications where simple DC speed control is useful. |
Simple speed control and strong starting torque in many designs. |
Brushes and the commutator wear and require maintenance; brush life and electrical noise should be considered. |
DC supply with voltage control or a DC drive. |
| Stepper Motor |
Electrical pulses energize stator phases in sequence, moving the rotor in discrete angular steps. |
Indexing tables, feeders, positioning stages, and lower-to-moderate-speed automation. |
Can provide repeatable open-loop positioning when load and operating conditions are suitable. |
May lose synchronism if overloaded; torque generally decreases as speed rises. Feedback may be added where position verification is important. |
Pulse-driven stepper controller, with optional encoder feedback. |
 Spiro Gear